Runtime Options
Runtime Options is the single seam that validates and applies MuJoCo’s runtime-tunable mjOption fields. ROS 1 and ROS 2 both translate transport requests into the same typed contract instead of parsing or mutating mjOption themselves.
Ownership
Runtime Options owns the typed RuntimeOptionsSnapshot/RuntimeOptionsPatch contract (runtime_options.hpp), field validation, and the mapping to and from mjOption. It does not own mjModel, mjData, or a persistent copy of the active options — ReadRuntimeOptions always reads back from the live model, so there is nothing to keep in sync.
The typed contract
RuntimeOptionsSnapshotis the complete set of fields — every option has a value.RuntimeOptionsPatchis the same fields, each wrapped instd::optional— a sparse set of changes.RuntimeOptionInput(fieldname + abool/int64/double/stringvariant) is the generic shape a transport adapter parses its own request into before handing it toParseRuntimeOptionsPatch.
Free functions do the actual work — ReadRuntimeOptions, ParseRuntimeOptionsPatch, ValidateRuntimeOptions, MergeRuntimeOptions, WriteRuntimeOptions — and are pure with respect to MujocoEnv: they take and return values, and never reach into simulation state themselves.
The live-update transaction
MujocoEnv::ApplyRuntimeOptions is the one entry point live callers use, and it runs the same four steps every time, all under physics_thread_mutex_:
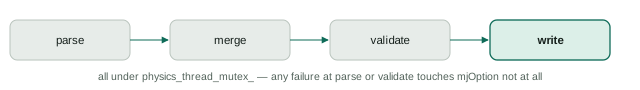
Four steps, always in this order, all under physics_thread_mutex_.
Any failure at parsing or validation returns immediately with a RuntimeOptionsError and touches model_->opt not at all. Only a fully validated candidate is written, and it is written as one assignment (a complete mjOption built from the candidate, then assigned) followed by incrementing OptionsEpoch — there is no intermediate state where some fields are updated and others are not.
The admission-epoch guard
Rejection during the loading window is guarded by two things, not one: the model lifecycle phase (must be kOperational) and a separate runtime_options_admission_epoch_ value that is read before physics_thread_mutex_ is even acquired, then compared again once it is held. The second check exists for a specific race: a caller could observe “we’re operational” an instant before a reload begins, then have to wait for physics_thread_mutex_ for the entire duration of that reload, and finally acquire it right as the new generation becomes operational. Without the epoch check, that caller’s patch — parsed and validated against intent formed before the reload — would silently land on a model it never actually observed. The epoch changing between the caller’s initial read and its eventual lock acquisition is what catches that.
The startup-only path
SetPendingRuntimeOptions is a separate path with a much narrower admission window: it is only accepted while there is no model loaded at all yet (ModelLifecyclePhase::kNoModel and model_ == nullptr). It parses and validates the patch eagerly — merged against a bare default snapshot — so a malformed startup patch is rejected immediately rather than being queued and discovered later. A patch that passes this check is stored and applied inside model loading itself, as one more merge+validate+write pass against the freshly loaded model’s real effective options.
The trade-off at that point is deliberate: if the startup patch fails validation against the real model (which can have different valid ranges than the default snapshot it was pre-checked against), the model load itself does not fail. The model stays valid and running with MuJoCo’s own effective options, and the failure is only recorded through the existing load-error channel. A simulation that would otherwise be perfectly loadable is not held hostage by one bad tuning value.